Research field
Soft and continuum robotics
We model, simulate and control bodies whose compliance is structural rather than commanded. Their very many degrees of freedom put them out of reach of classical rigid-body methods.
About this field
Robots whose compliance lives in the body rather than in the controller. We model, simulate and control continuum structures whose effectively infinite degrees of freedom put them out of reach of classical rigid-body methods.
People
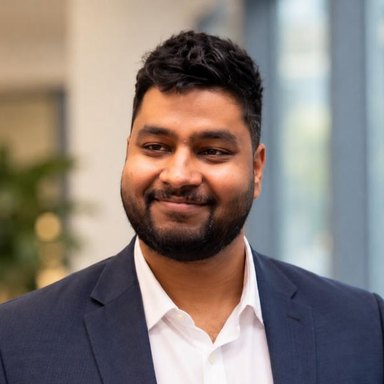
Hozefa Jesawada
The research covers safe learning-based control for soft and continuum robots. It also develops Grassmannian methods for null-space control.
Hozefa Jesawada is a Postdoctoral Researcher at New York University Abu Dhabi. He earned his PhD in Information Technologies for Engineering from the University of Sannio, Italy, and subsequently worked as a postdoctoral researcher at the University of Salerno. His research focuses on reliable decision-making and control for robotics, combining tools from optimization, uncertainty-aware learning, inverse optimal control, and robust planning.
He is particularly interested in how principled learning methods can support embodied intelligence in real robotic systems, including manipulation, model-based formal control, and safety-aware autonomy.
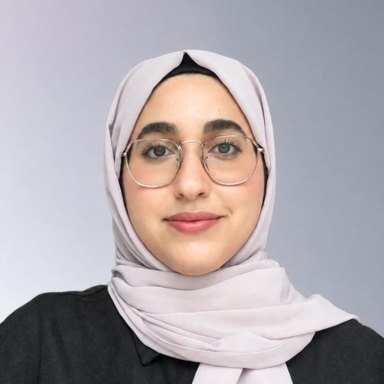
Ikhlas Ben Hmida
The research covers the modelling and design of a soft prosthetic hand. It also explores data-driven decoding of hand and finger motion from surface electromyography.
Ikhlas Ben Hmida is a Global Ph.D. fellow from NYU Tandon School of Engineering and a visiting graduate research assistant at the REACH Lab at NYUAD, where she is conducting her PhD research.
Her research interests include soft robotics, bio-inspired systems, and medical applications of robotics. She is currently exploring data-driven approaches to decoding hand and finger motion from surface electromyography (sEMG) to advance human-machine interfaces and dexterous prosthetic and assistive hands.
Publications since 2024
A Framework for Soft Robot Control: Integrating Physics-Based Modeling with Exploration-Based Learning
IEEE International Conference on Robotics and Automation (ICRA)
@inproceedings{armanini2026framework,
  author    = {Armanini, C. and Tzes, A. and Del Prete, A. and Abu-Dakka, F.},
  title     = {{A Framework for Soft Robot Control: Integrating Physics-Based Modeling with Exploration-Based Learning}},
  booktitle = {IEEE International Conference on Robotics and Automation (ICRA)},
  year      = {2026},
  address   = {Vienna, Austria}
}