Research field
Decision-making under uncertainty
We use free-energy and active-inference formulations to treat exploration and robustness as one problem. This lets a robot act well without an exact model of the world.
About this field
Acting well without an exact model of the world. Free-energy and active-inference formulations that treat exploration and robustness as two faces of one problem rather than as competing objectives to be traded off.
People
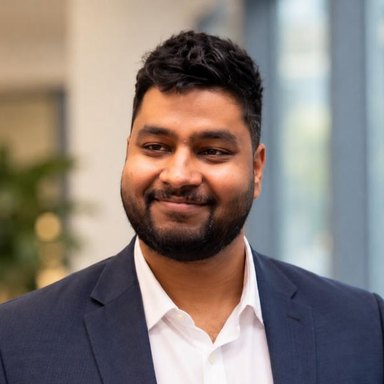
Hozefa Jesawada
The research covers safe learning-based control for soft and continuum robots. It also develops Grassmannian methods for null-space control.
Hozefa Jesawada is a Postdoctoral Researcher at New York University Abu Dhabi. He earned his PhD in Information Technologies for Engineering from the University of Sannio, Italy, and subsequently worked as a postdoctoral researcher at the University of Salerno. His research focuses on reliable decision-making and control for robotics, combining tools from optimization, uncertainty-aware learning, inverse optimal control, and robust planning.
He is particularly interested in how principled learning methods can support embodied intelligence in real robotic systems, including manipulation, model-based formal control, and safety-aware autonomy.
Publications since 2024
Learning-Based Robust Control: Unifying Exploration and Distributional Robustness for Reliable Robotics via Free Energy
IEEE International Conference on Robotics and Automation (ICRA)
@inproceedings{jesawada2026learningbased,
  author        = {Jesawada, H. and Russo, G. and Swikir, A. and Abu-Dakka, F.},
  title         = {{Learning-Based Robust Control: Unifying Exploration and Distributional Robustness for Reliable Robotics via Free Energy}},
  booktitle     = {IEEE International Conference on Robotics and Automation (ICRA)},
  year          = {2026},
  address       = {Vienna, Austria},
  eprint        = {2603.06831},
  archivePrefix = {arXiv}
}